Predicting intent before the force fully arrives.
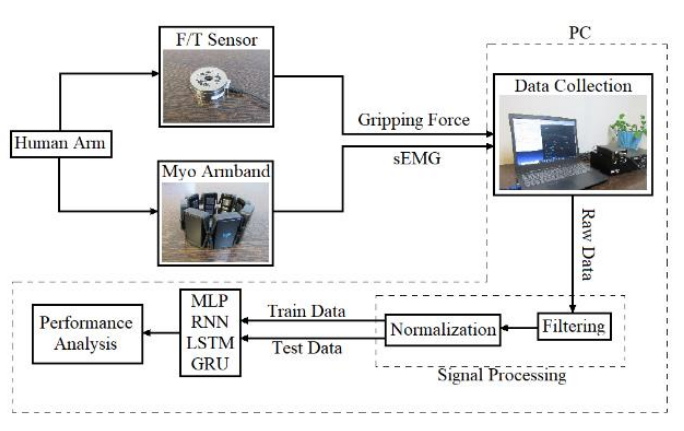
This research estimates hand grip force from surface electromyography signals. The model learns the temporal relationship between muscle activation and measured force, enabling both accurate estimation and early prediction.
I designed the recurrent neural-network model and worked with synchronized pressure and sEMG data. The resulting approach supports more responsive prosthetic hands and other human-centered assistive devices.
Key contributions
- Designed GRU and LSTM architectures for continuous force estimation.
- Combined synchronized pressure-sensor and surface-EMG measurements.
- Evaluated early prediction as well as same-time force reconstruction.
- Connected the results to prosthetic and assistive-robot control applications.