Repairing a machine for the environment it actually faces.
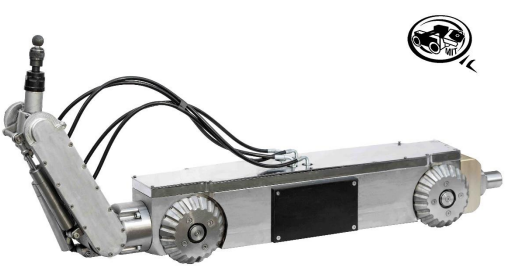
This bachelor’s project focused on restoring and improving a hydraulic sewer-line inspection robot. The work required understanding the failure modes of an existing platform and redesigning subsystems for reliability, serviceability, and field performance.
After mechanical and hydraulic repair, the rebuilt robot was tested in a laboratory environment to verify subsystem function before deployment.
Key contributions
- Diagnosed failures across the hydraulic and mechanical subsystems.
- Redesigned critical mechanisms to improve operational reliability.
- Repaired, assembled, and commissioned the robot.
- Designed and carried out laboratory functional tests.


