 01
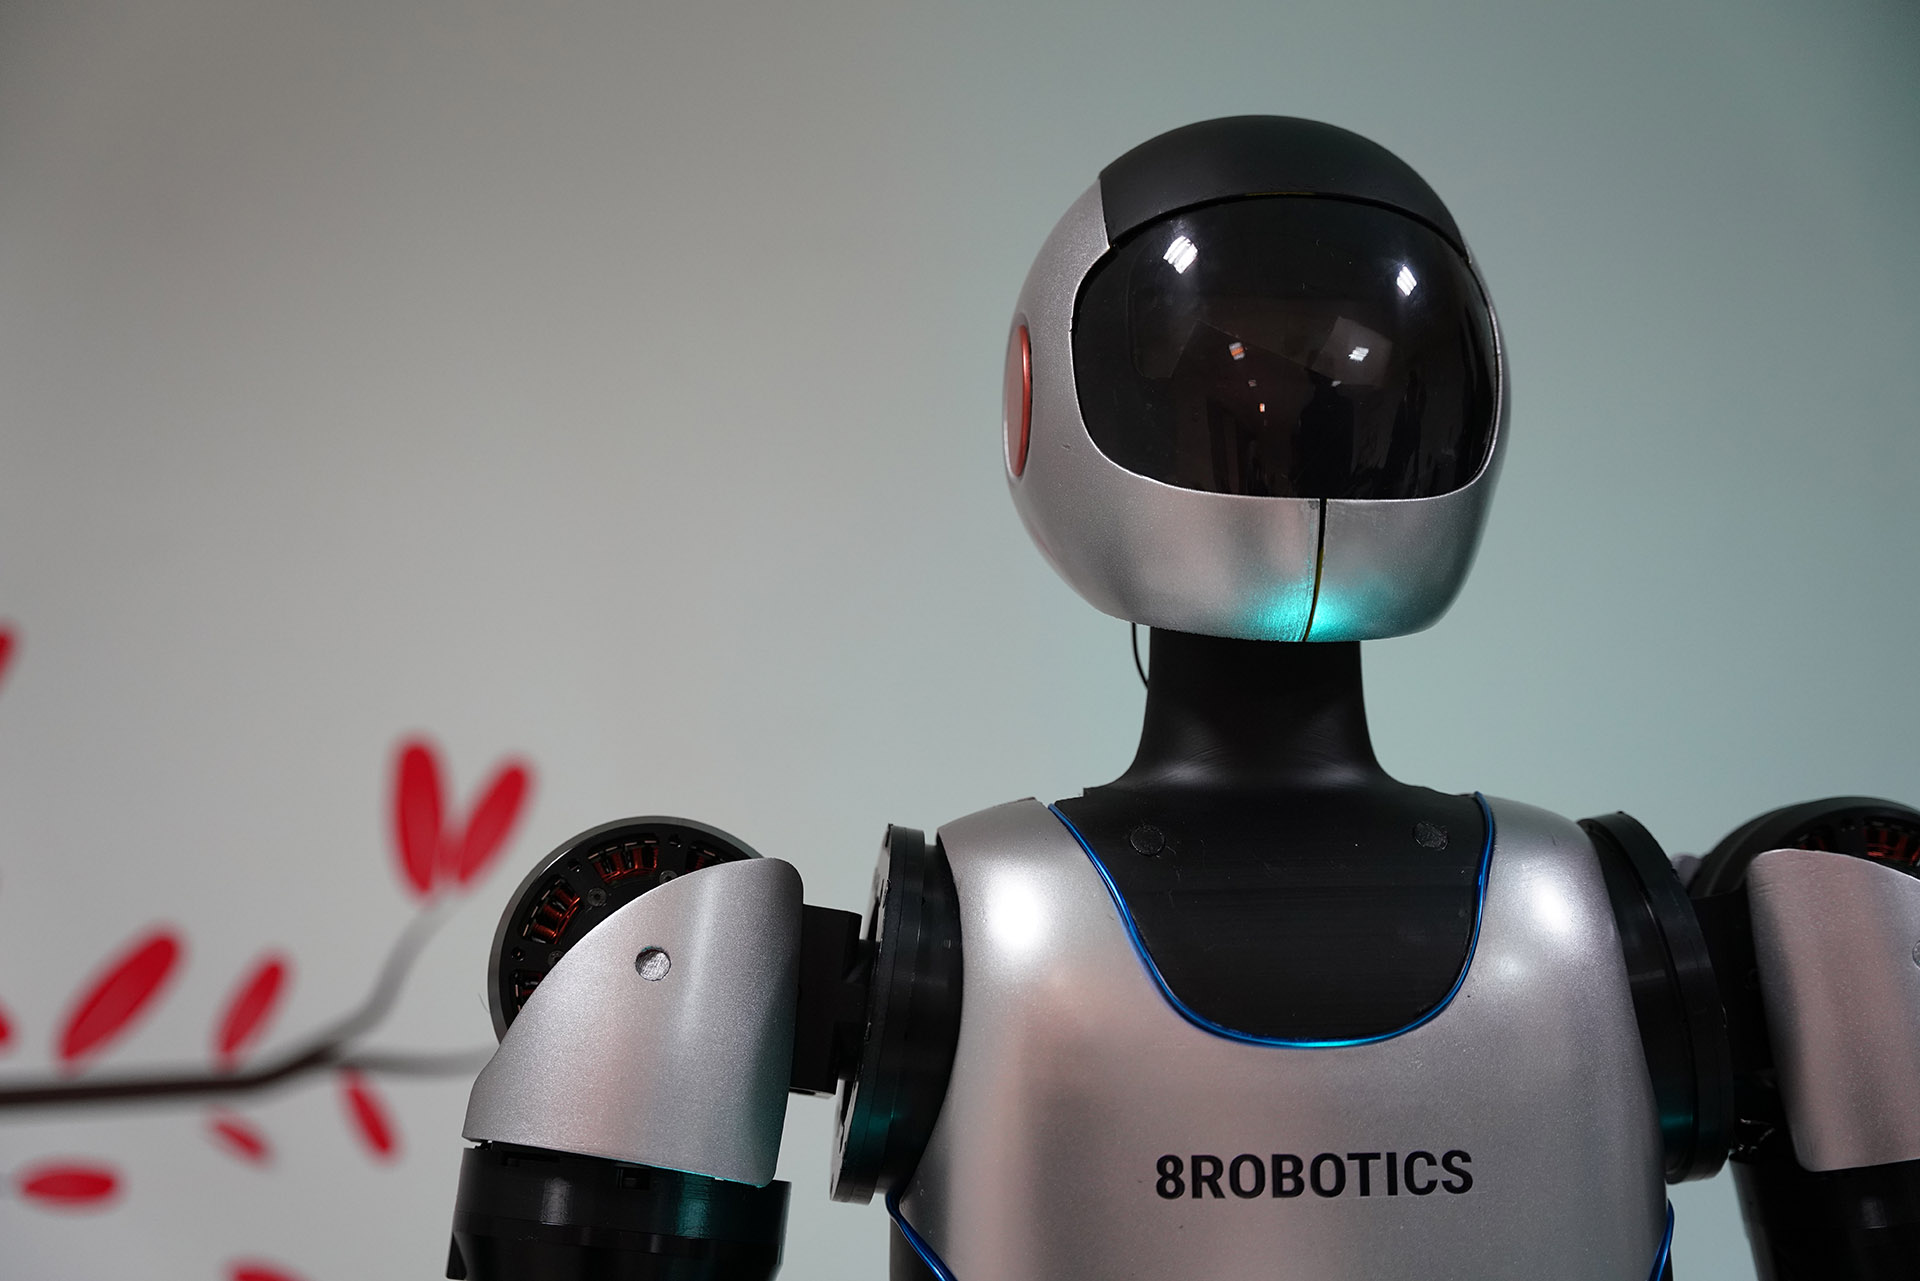
ILIA Humanoid Platform
First-prototype integration across robot electronics, firmware, ROS/DDS, control, autonomy, and learning-based development.
Open project ↗Project record / 10 systems
Selected work across humanoid locomotion, robot learning, sensor fusion, mapping, human-machine interaction, and real-time perception.
01First-prototype integration across robot electronics, firmware, ROS/DDS, control, autonomy, and learning-based development.
Open project ↗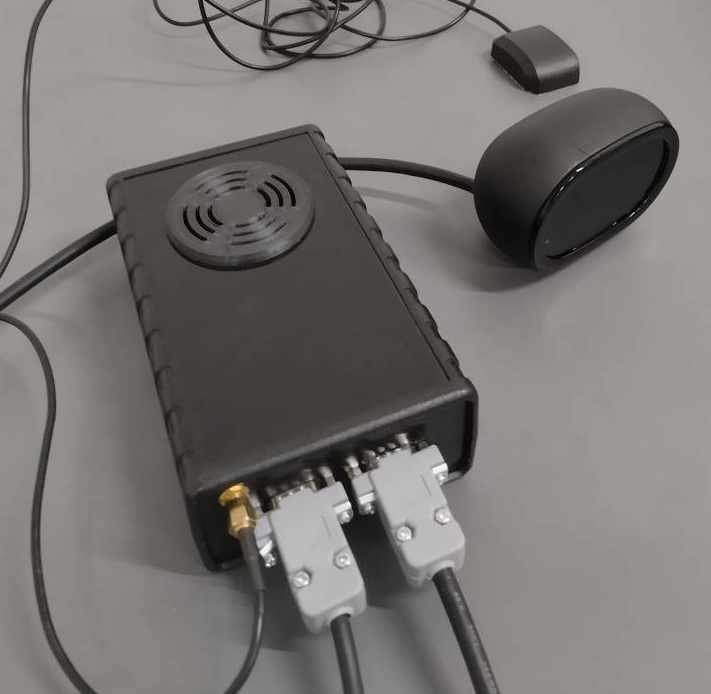 02
Face-mesh, head-pose, drowsiness, and distraction detection with vehicle and cloud communication.
Open project ↗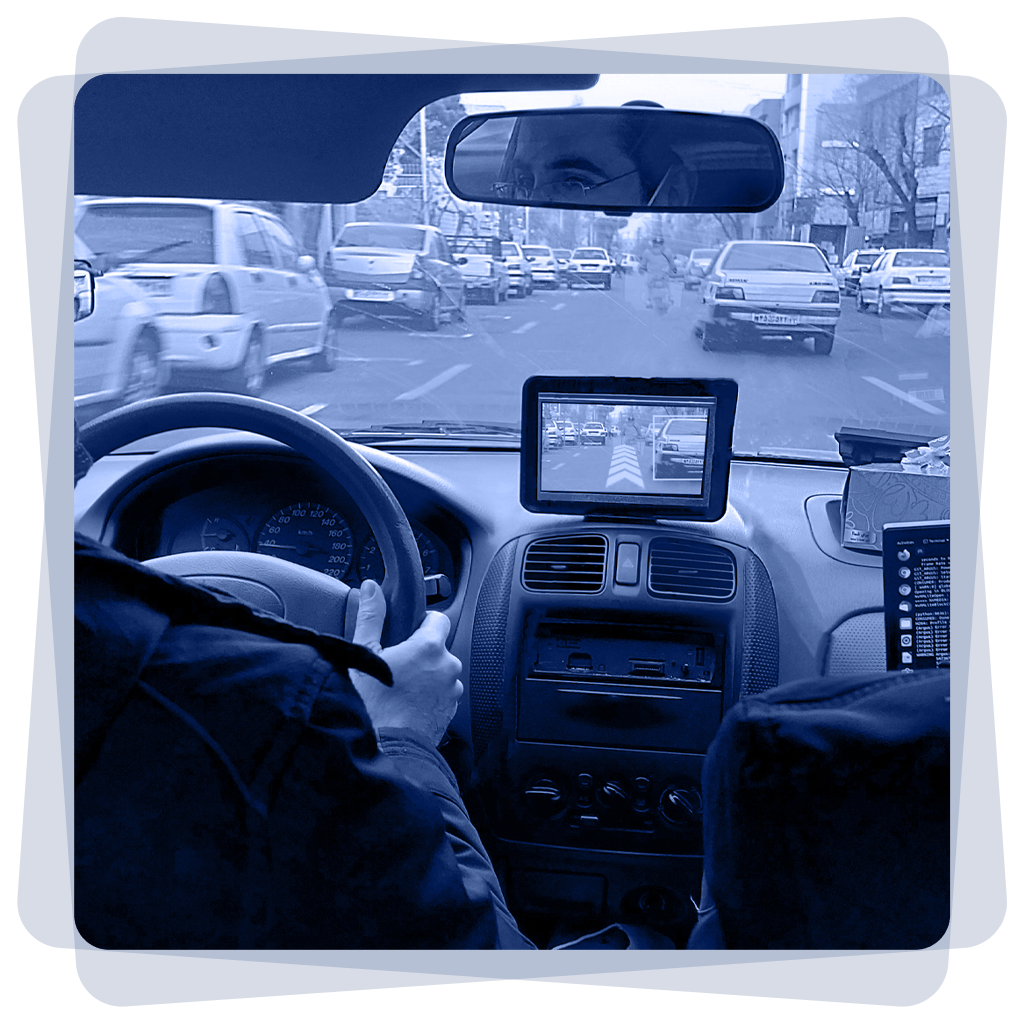 03
Real-time monocular detection, tracking, range estimation, alerting, and CARLA-based system validation.
Open project ↗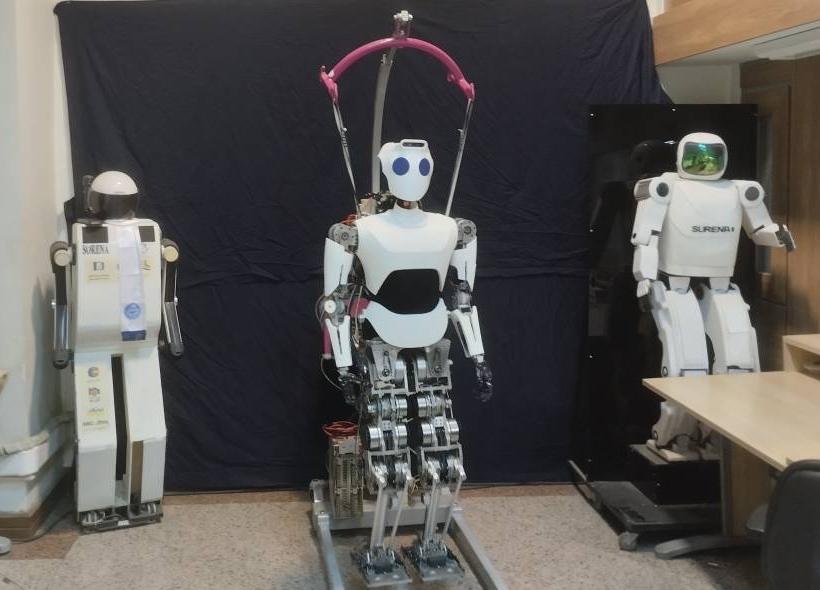 04
Trajectory planning, locomotion control, simulation, hardware integration, and technical leadership for a full-scale humanoid platform.
Open project ↗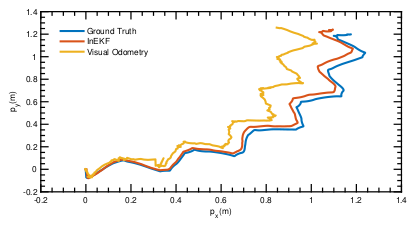 05
Invariant extended Kalman filtering on Lie groups, fusing inertial measurements with humanoid forward kinematics.
Open project ↗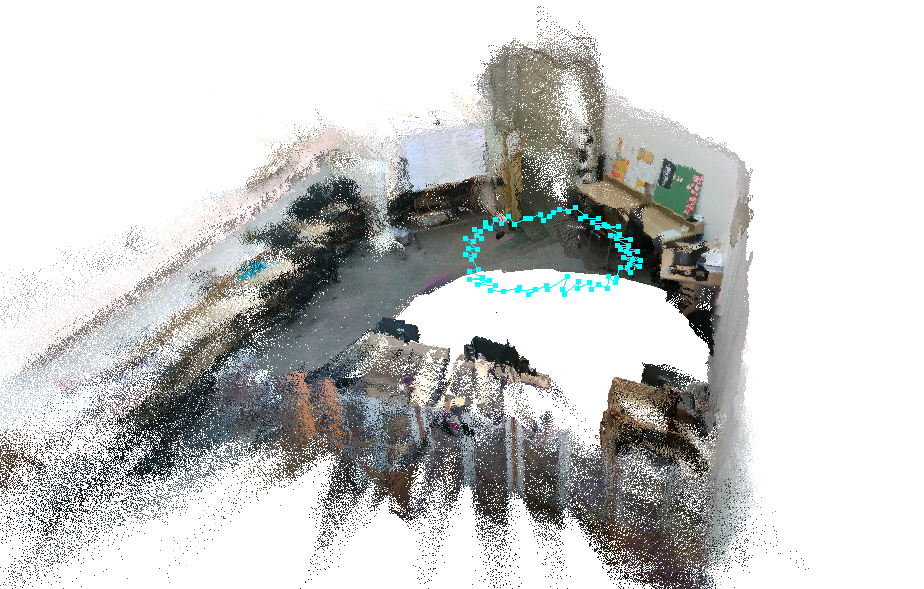 06
Comparative mapping pipeline evaluation and proprioceptive odometry integration for robust humanoid navigation.
Open project ↗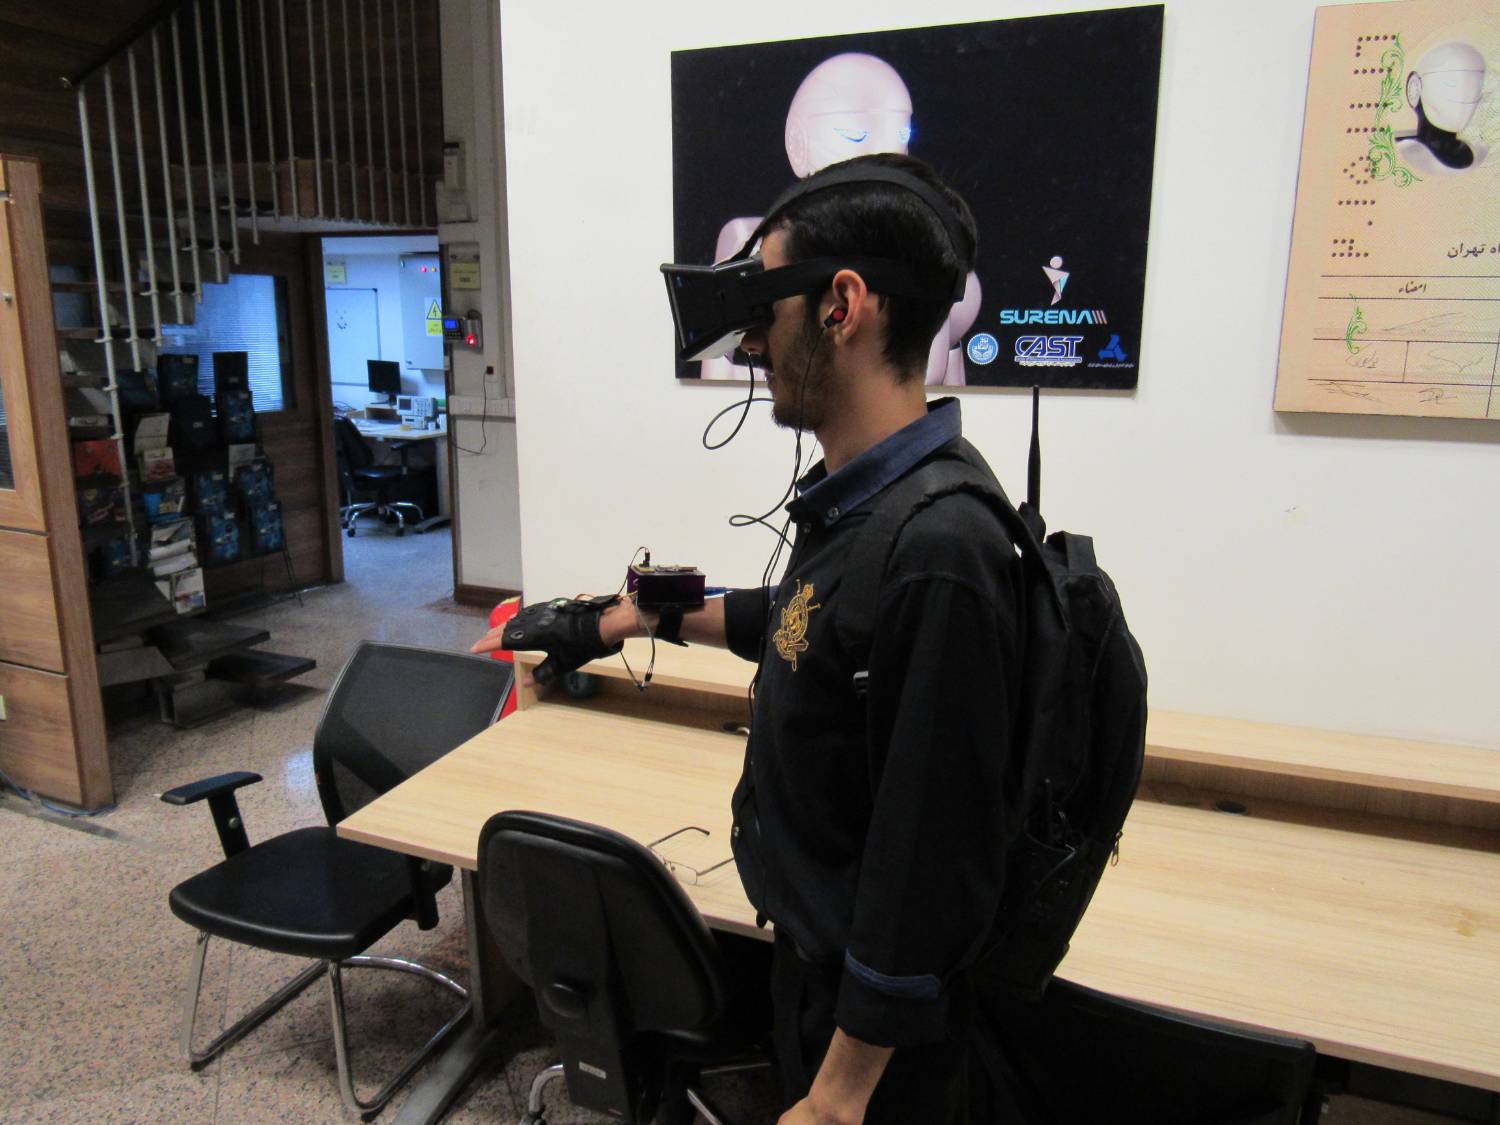 07
Gesture-based mobile-robot control with inertial sensing and real-time wireless audio/video feedback.
Open project ↗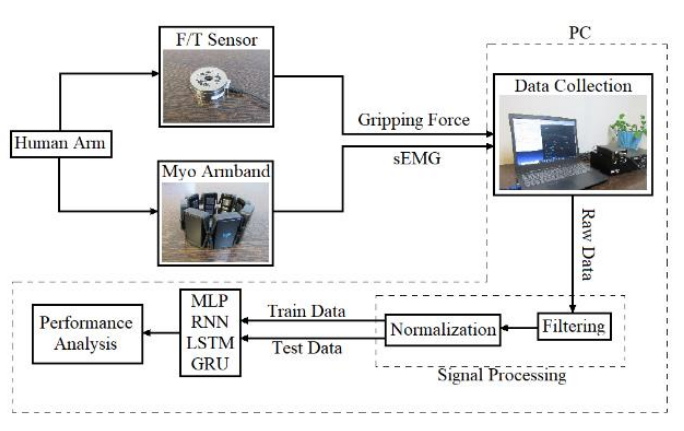 08
Early grip-force prediction using surface electromyography and deep recurrent GRU/LSTM models.
Open project ↗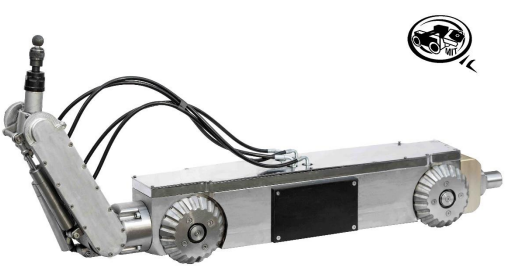 09
Hydraulic and mechanical subsystem redesign, repair, and laboratory testing for an inspection robot.
Open project ↗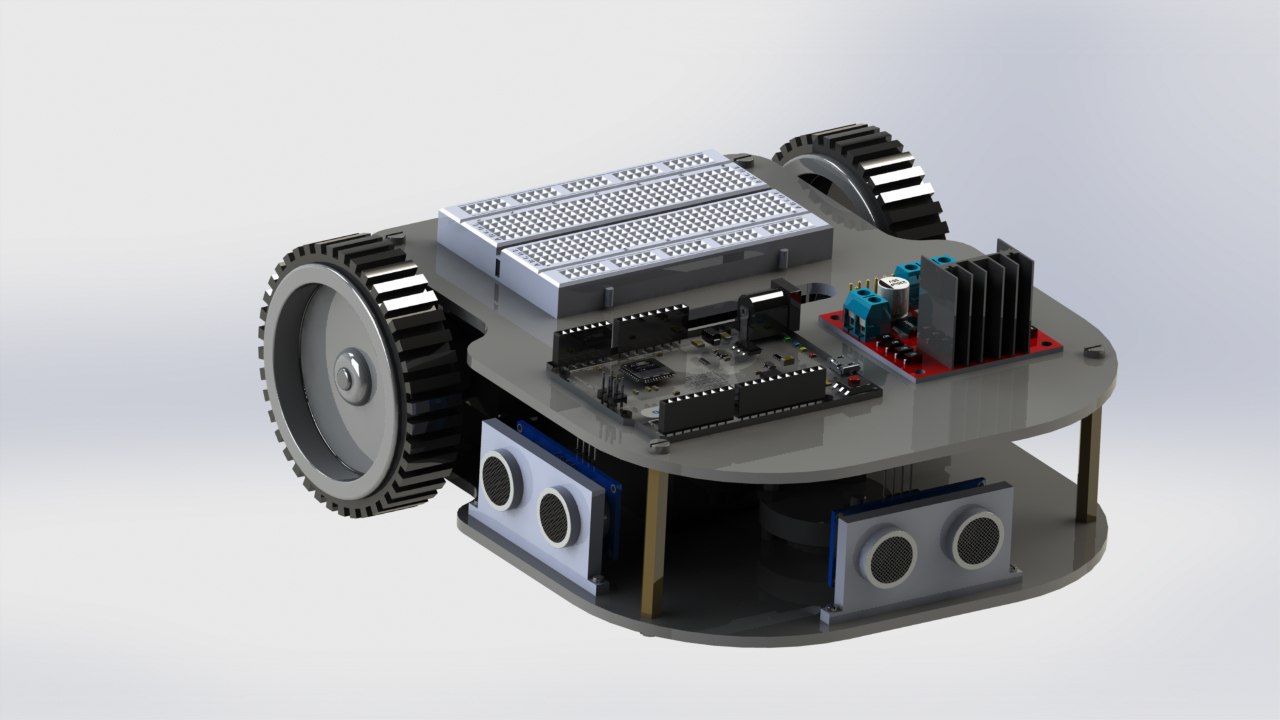 10
Ultrasonic wall perception and autonomous path logic for a compact educational mobile robot.
Open project ↗Next system
I welcome research collaborations and technically ambitious robotics work.