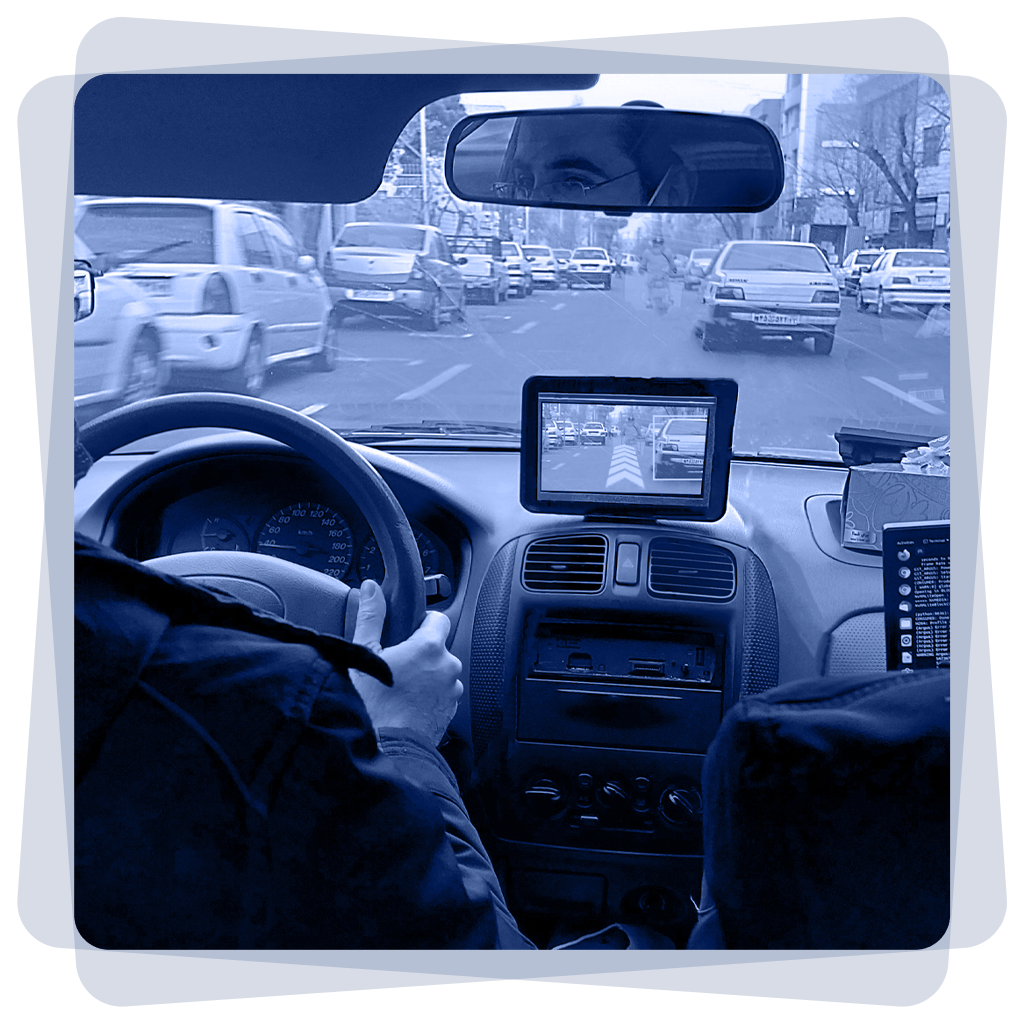
Useful warnings from a single camera.
The pre-collision warning system turns monocular video into a continuously updated picture of nearby road risk. It combines object detection and tracking with range estimation and warning logic tuned for real-time operation.
Before in-vehicle evaluation, the pipeline was simulated and tested in CARLA. This allowed repeatable validation across traffic configurations and edge cases while the algorithms were optimized for embedded deployment.
Key contributions
- Implemented and optimized real-time neural object detection and multi-object tracking.
- Developed monocular distance estimation and forward-collision warning logic.
- Created CARLA scenarios for repeatable simulation and algorithm validation.
- Supported embedded-system optimization and road testing.

