Reliable state estimates when vision is not enough.
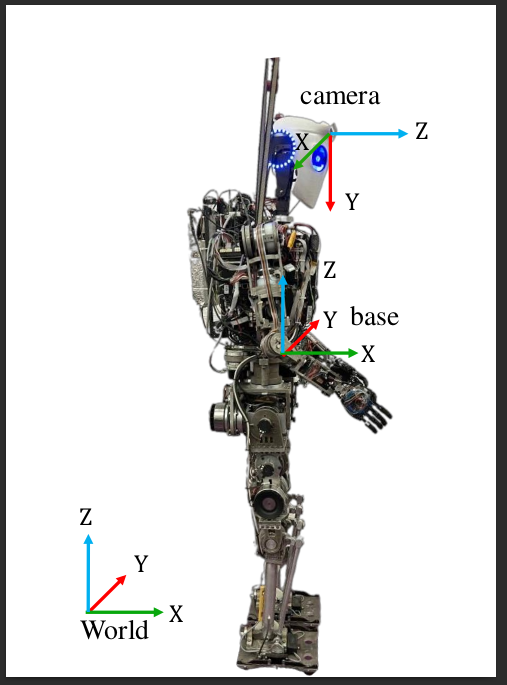
A walking humanoid needs a stable estimate of its floating base even when visual features are weak or the machine moves quickly. This thesis work uses IMU equations for prediction and forward-kinematic constraints for correction.
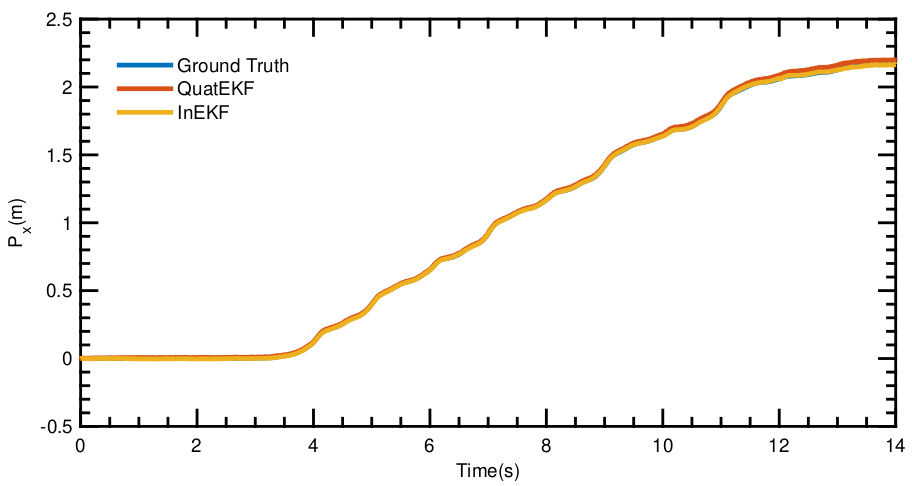
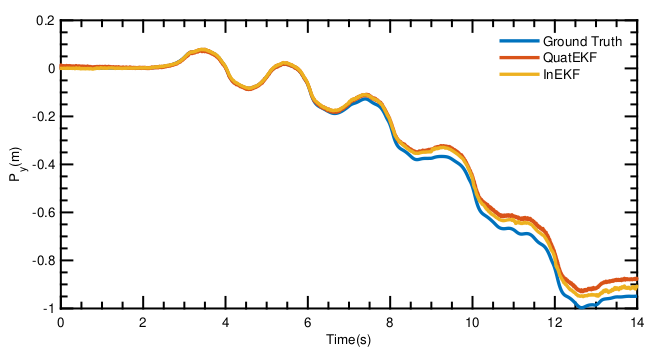
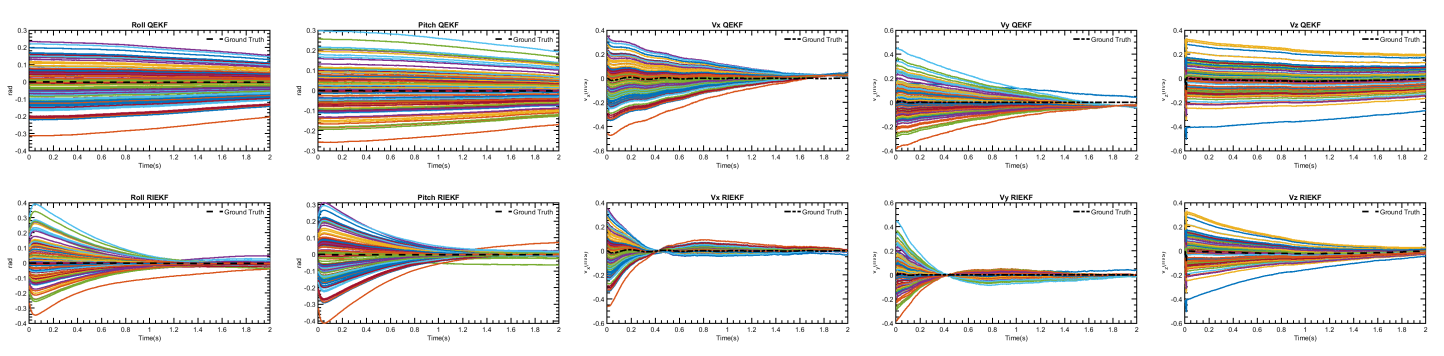
I studied quaternion extended Kalman filtering and invariant filtering on matrix Lie groups. The invariant formulation gives an autonomous error model under specific conditions and a linear structure in logarithmic coordinates; in Choreonoid simulations, it converged faster and more consistently than the alternatives we evaluated.
Key contributions
- Implemented quaternion and invariant extended Kalman filters for humanoid base-state estimation.
- Fused IMU dynamics with contact-aware forward-kinematic measurements.
- Analyzed the Lie-group error formulation and convergence behavior across varied initial states.
- Integrated the estimator’s odometry output into the downstream mapping pipeline.