Simple sensing, deliberate behavior.
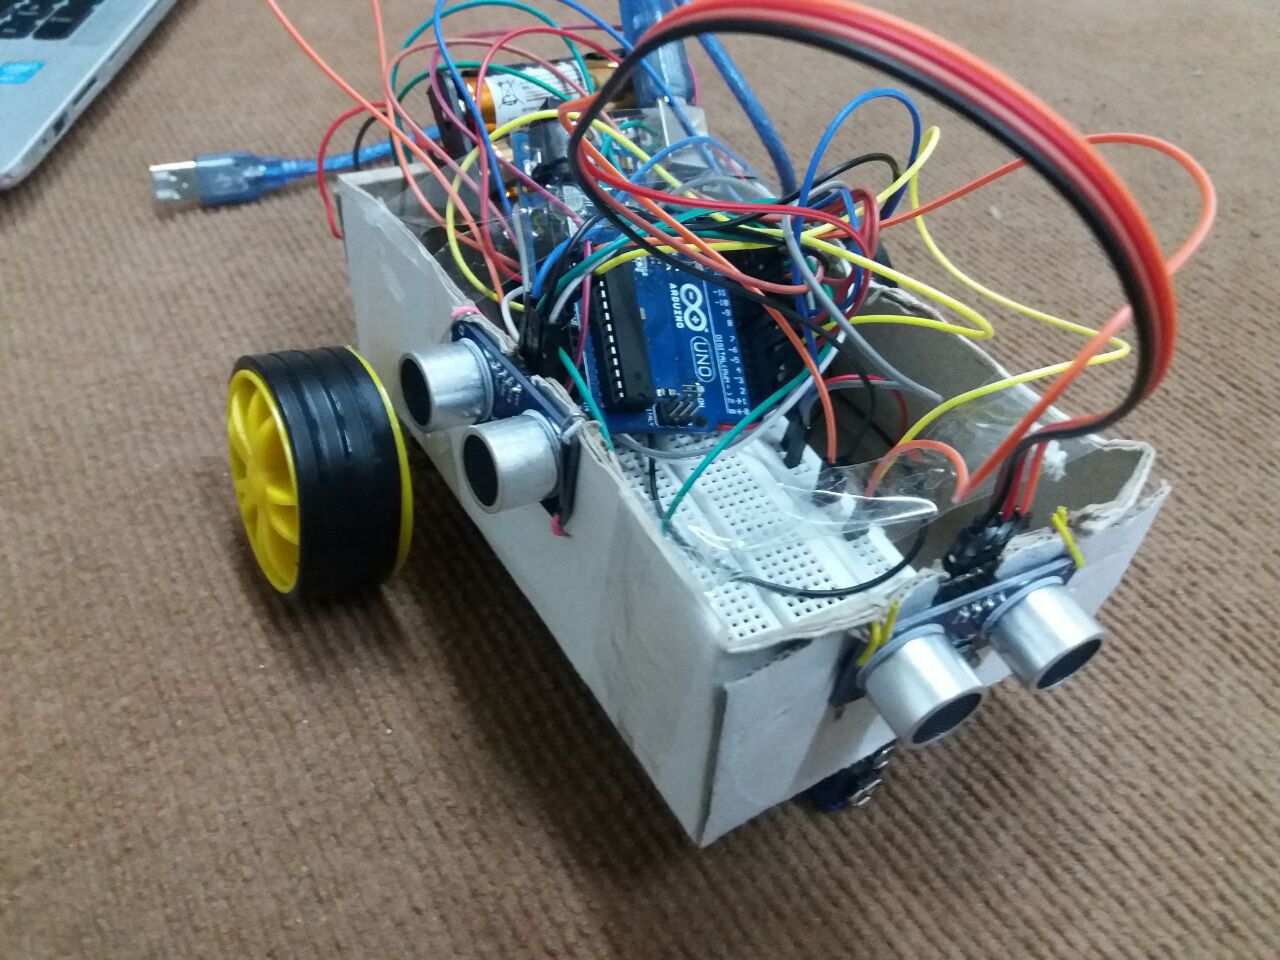
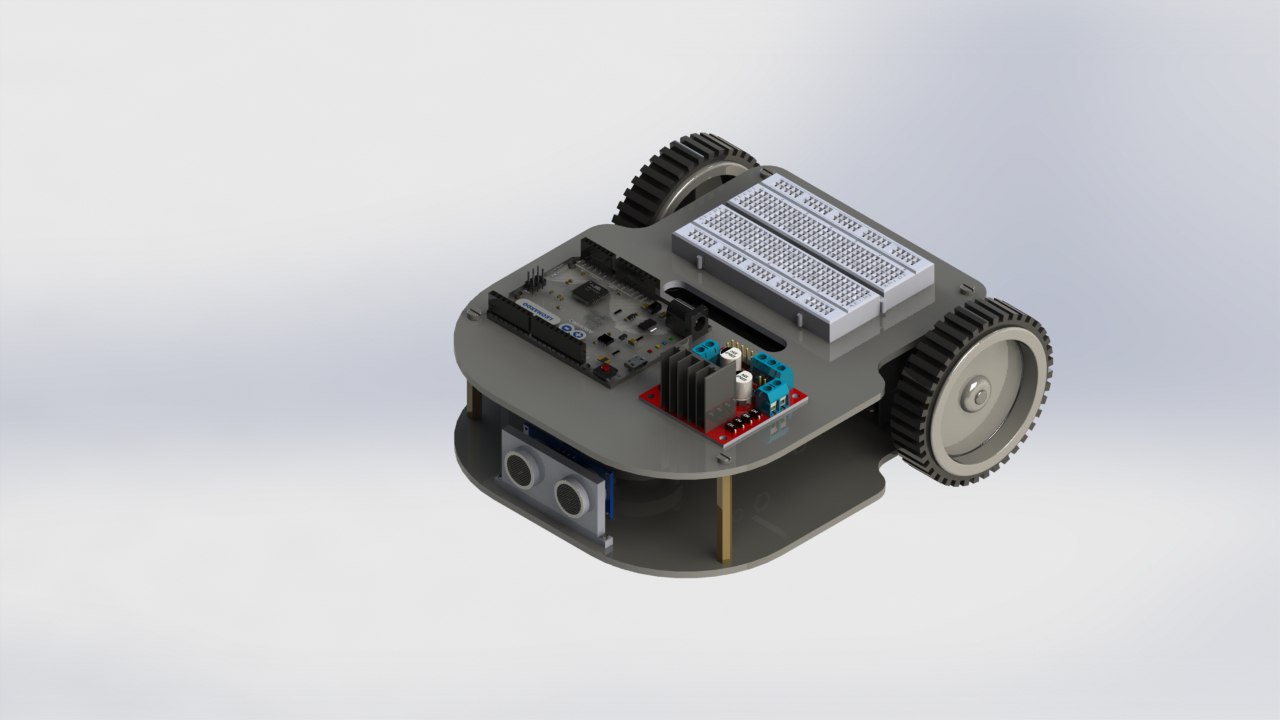
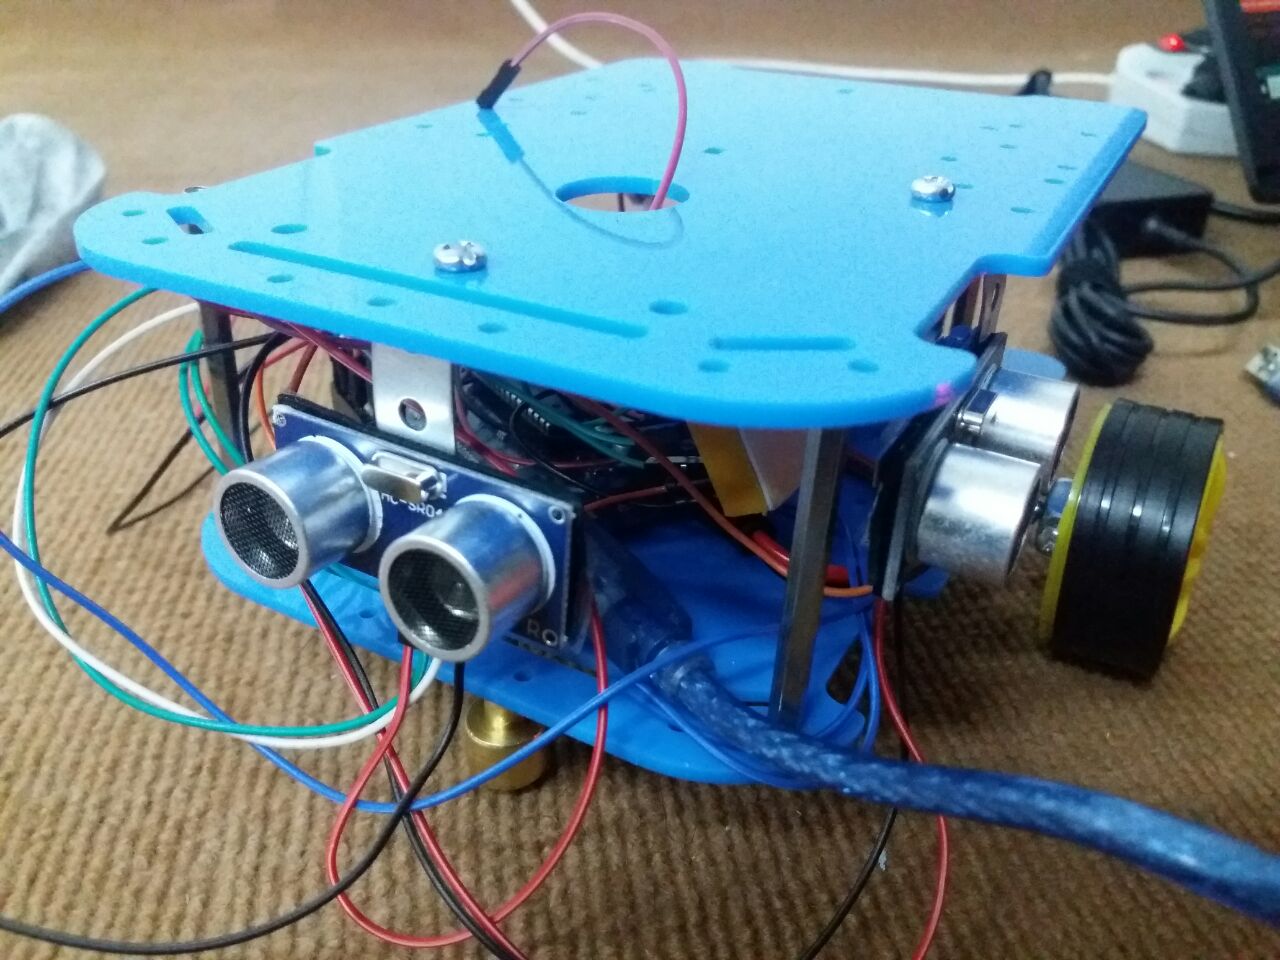
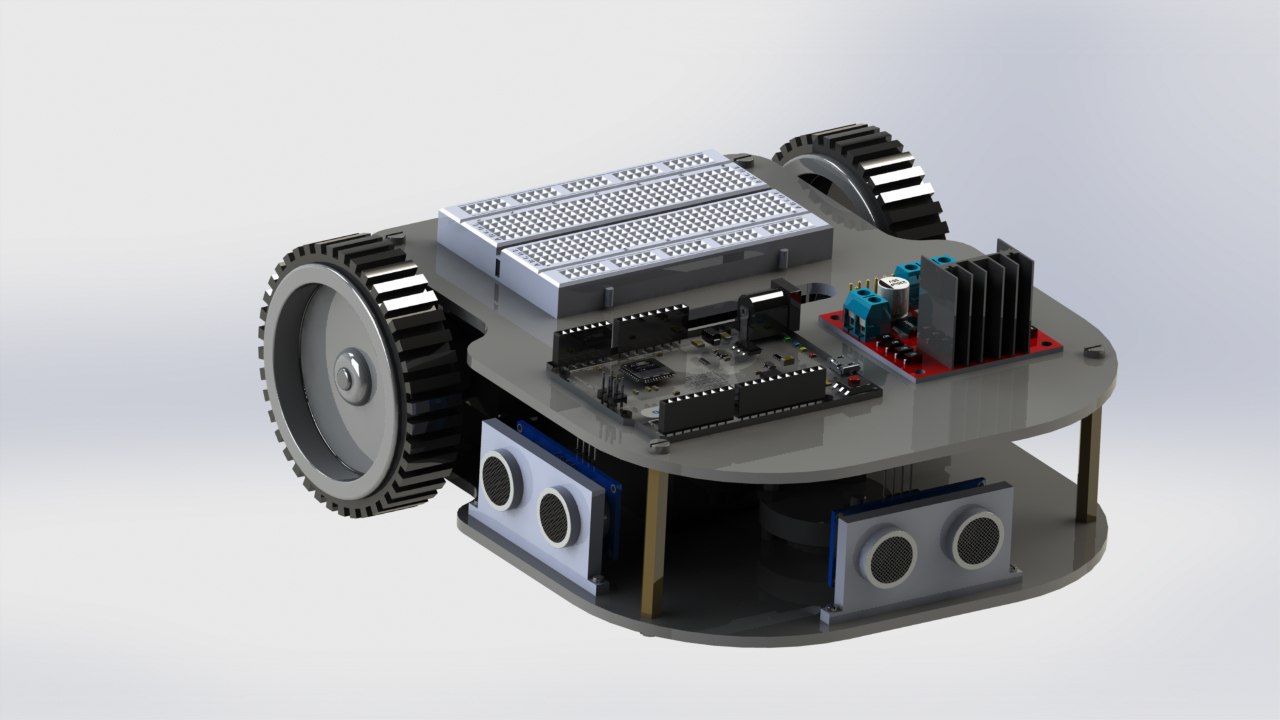
This course project built a compact robot capable of navigating a maze without external localization. Ultrasonic sensors measured wall distances while onboard logic converted those local observations into steering decisions.
The result was an end-to-end mechatronic system: mechanical chassis, sensing, actuation, embedded logic, and autonomous testing in a physical maze.
Key contributions
- Integrated ultrasonic sensors for reliable wall-distance measurement.
- Designed the embedded navigation and escape algorithm.
- Built and wired the compact mobile platform.
- Tested path behavior and refined thresholds in a physical maze.