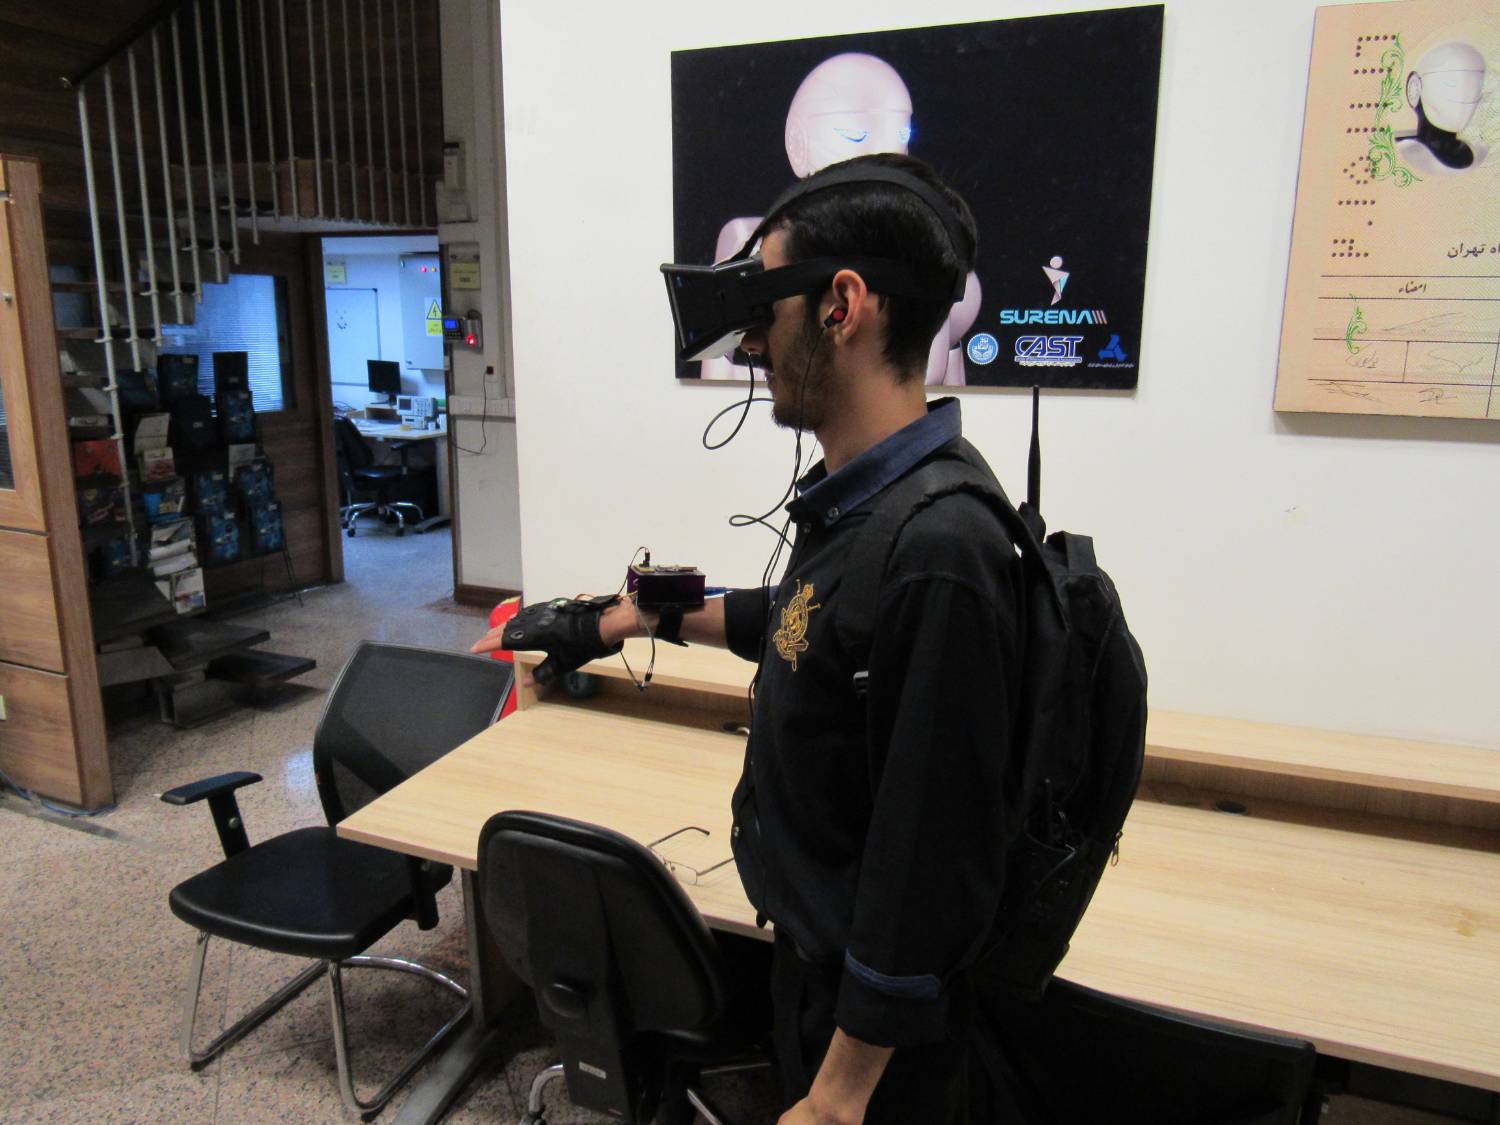
Controlling motion with movement that already feels natural.
The smart-glove project explored a more direct way to teleoperate a mobile robot: map a person’s hand gestures and inertial motion to robot commands, then return the robot’s visual and audio perspective through wearable displays.
The complete loop combined embedded sensing, gesture interpretation, wireless control, and low-latency feedback to make remote operation more intuitive and immersive.
Key contributions
- Mapped inertial hand gestures to mobile-robot motion commands.
- Designed the wearable sensing and interaction pipeline.
- Implemented wireless transport for command, image, and audio data.
- Integrated real-time robot feedback with the user’s wearable display.