Mapping from a platform that never stands perfectly still.
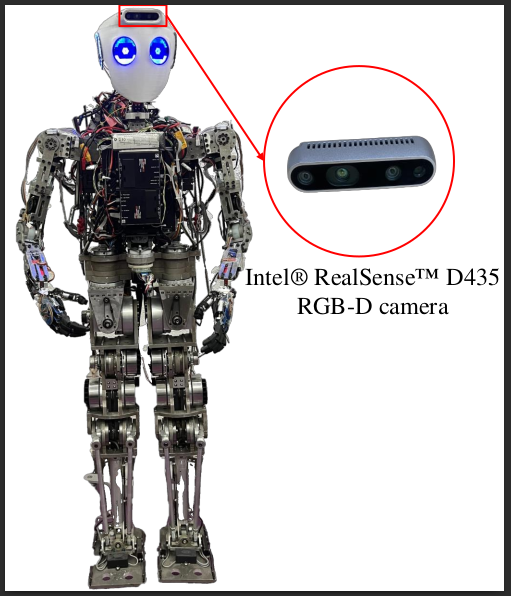
Visual odometry on a humanoid is challenged by fast body motion, changing illumination, and the repeated texture of indoor environments. I evaluated multiple RGB-D SLAM methods and then used the base estimator’s proprioceptive odometry to strengthen RTAB-Map.
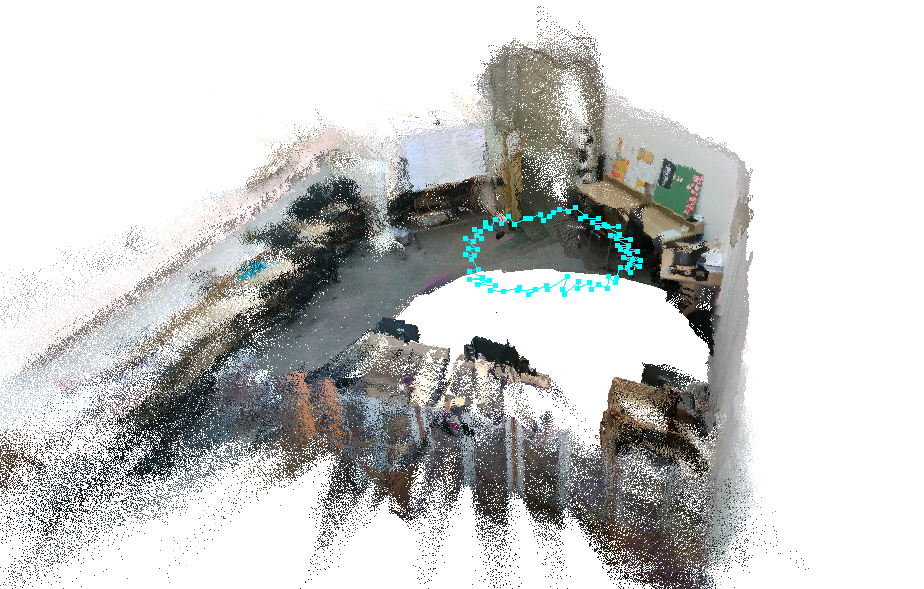
The resulting pipeline avoided part of the visual system’s feature and lighting dependence while updating faster during dynamic motion. It produced both dense 3D maps and 2D occupancy grids in Choreonoid environments for downstream path planning.
Key contributions
- Implemented and compared several RGB-D localization and mapping algorithms.
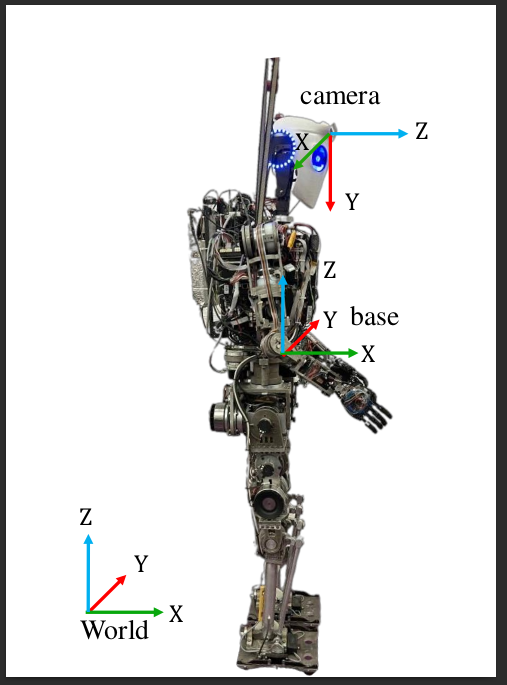
- Replaced visual odometry with higher-rate proprioceptive odometry from the invariant estimator.
- Generated dense point-cloud maps and two-dimensional occupancy grids.
- Evaluated suitability for humanoid navigation under dynamic motion.