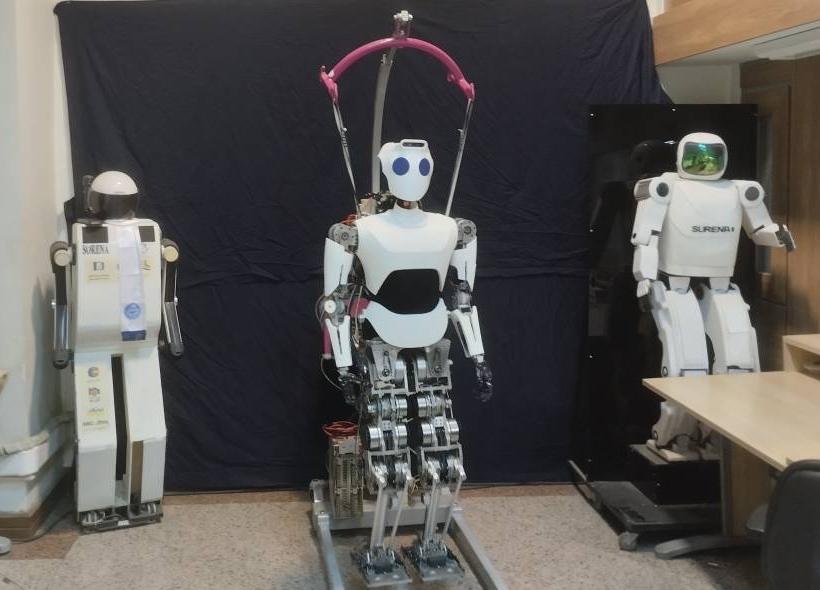
From control architecture to physical machine.
At the Center of Advanced Systems & Technologies, I worked across the Surena-V program from research and simulation to implementation and experimental validation. As senior developer and dynamics-and-control lead, I helped translate a complex full-body control problem into software that could run on the robot.
The work combined trajectory generation, model-based control, state estimation, system integration, and repeated hardware experiments. I also established and maintained the project’s GitHub organization to make development and collaboration more systematic.
Key contributions
- Designed and implemented trajectory-planning and control algorithms for robust bipedal locomotion.
- Simulated control strategies, then integrated and validated them on the physical humanoid platform.
- Contributed to actuator and structural-component design, manufacturing, and robot assembly.
- Led the dynamics and control team and supported junior and graduate researchers.
Development archive
Surena-V grew through simulation, hardware integration, repeated experiments, and teamwork. These records show the process behind the finished platform.